2011 INFINITI QX56 Map sensor
[x] Cancel search: Map sensorPage 158 of 5598

AV-10
< SYSTEM DESCRIPTION >
COMPONENT PARTS
Component Description
INFOID:0000000006216214
1. Squawker RH 2. Center speaker 3. Corner sensor front RH
4. Squawker LH 5. Front camera 6. Corner sensor front LH
7. Side camera LH 8. Front door speaker LH 9. Headrest display unit LH
10. Rear door tweeter LH 11. Rear door speaker LH 12. Roof speaker LH
13. Woofer 14. Corner sensor rear LH 15. Satellite radio antenna
16. Rear camera 17. Corner sensor rear RH 18. BOSE amp.
19. Roof speaker RH 20. Antenna amp. 21. Rear door speaker RH
22. Rear door tweeter RH 23. Headrest display unit RH 24. Front door speaker RH
25. Side camera RH and infrared LED
(auxiliary lighting) 26. Front display unit 27. Steering switch
28. Sonar control unit 29. Steering angle sensor 30. Preset switch
31. Around view monitor control unit 32. USB connector 33. Front auxiliary input jacks
34. Rear auxiliary input jacks 35. AV control unit 36. Video distributor
37. Multifunction switch 38. GPS antenna 39. Microphone A. Luggage side lower finisher LH re-
moved condition B.Luggage side lower finisher RH re-
moved condition C.Headlining assembly removed condi-
tion
D. Instrument lower
panel LH removed
condition E. Spiral cable part F. Cluste
r lid C removed condition
G. Within center console H. Instrument panel rear side
Part name Description
AV control unit Integrates hard disk drive (HDD) allowing map data and music data to be stored.
It is the master unit of the MULTI AV system, and it is connected to each control
unit by communication. It operates each system according to communication sig-
nals from the AV control unit.
The AV control unit includes the audio, hands-free phone, navigation, USB con- nection, DVD play and vehicle information functions.
It is connected to ECM and combination meter via CAN communication to obtain
necessary information for the vehicle information function.
It inputs the illumination signals that are required for the front display dimming con- trol.
It inputs the signals for driving status recognition (vehicle speed, reverse and park- ing brake).
The RGB digital image signal and composite image signal are output to front dis-
play unit.
Switches image and sound output to video distributor, inputting image switch sig- nal from headrest display unit via AV communication.
Amp. ON signal and mode change signal transmitted to BOSE amp.
Update of map data is performed with the DVD-ROM.
Front display unit Front display image is controlled by the serial communication from AV control unit.
RGB digital image signal is input from AV control unit.
Composite image signal is input from AV control unit.
Camera image signal is input from around view monitor control unit.
Touch panel function can be operated for each system by touching a display di-
rectly.
Headrest display unit Composite image signal [USB (video data), DVD and auxiliary input images] is in-
put from the video distributor.
It receives the DVD/AUX/USB sound signal from the video distributor, and then transmits it to the headphones.
Outputs image switch signal to video distributor via hard wire, according to rear seat remote controller operation.
Outputs image switch signal to AV control unit via AV communication, according to
rear seat remote controller operation.
Revision: 2010 May2011 QX56
Page 162 of 5598

AV-14
< SYSTEM DESCRIPTION >
SYSTEM
MULTI AV SYSTEM : System Description
INFOID:0000000006216216
Multi AV system means that the following systems are integrated.
COMMUNICATION SIGNAL
AV control unit function by transmitting/receiving dat a one by one with each unit (slave unit) that configures
them completely as a master unit by connecting between units that configure MULTI AV system with two AV
communication lines (H, L).
Two AV communication lines (H, L) adopt a twisted pair line that is resistant to noise.
AV control unit is connected by CAN communication, and it receives data signal from ECM and combination
meter It computes and displays fuel economy information value with the obtained information. Transmitting/
receiving of data signal is performed by BCM. Also, it transmits the required signal of vehicle setting and
receives the response signal.
AV control unit is connected with front display unit and serial communication, and it transmits the required
signal of display and display control and receives the response signal from front display unit.
NAVIGATION SYSTEM FUNCTION
Description
The AV control unit controls navigation function whil e GPS tuner has built-in map data, GYRO (angle speed
sensor), on the HDD (Hard Disk Drive).
The AV control unit inputs operation signal with communication signal, through display (touch panel) and multifunction switch and steering switch.
Guide sound is output to front speaker through BOSE am p. from AV control unit when operating navigation
system.
A vehicle position is calculated with the GYRO (angl e speed sensor), vehicle sensor, signal from GPS satel-
lite and map data stored on HDD (Hard Disk Drive), and transmits the map image signal (RGB image, RGB
area, RGB image synchronizing) to the display.
Position Detection Principle
The navigation system periodically calculates the current vehicle
position according to the following three types of signals.
Travel distance of the vehicle as determined by the vehicle speed
sensor
Vehicle turning angle determined by the gyroscope (angular speed
sensor)
The travel direction of the v ehicle determined by the GPS antenna
(GPS information)
The current position of the vehicle is then identified by comparing the
calculated vehicle position with map data, which is stored in the HDD
(Hard Disk Drive) (map-matching), and indicated on the screen with
a current location mark. More accurate data is used by comparing
position detection results from GPS to the map-matching.
FUNCTION NAME
Navigation system function Audio function
DVD play function
Front auxiliary input function USB connection function
Mobile entertainment system Hands-free phone function Touch panel function
Around view monitor function
Camera assistance sonar system Vehicle information function
Auto Light adjustment system
JSNIA0177GB
Revision: 2010 May2011 QX56
Page 163 of 5598

AV
SYSTEMAV-15
< SYSTEM DESCRIPTION >
C
DE
F
G H
I
J
K L
M B A
O P
The current position is calculated by detecting the travel distance
from the previous calculation point, and its direction change.
Travel distance The travel distance is generat ed from the vehicle speed sensor
input signal. The automatic distance correction function is adopted
for preventing a miss-detection of the travel distance because of
tire wear etc.
Travel direction The gyroscope (angular veloci ty sensor) and GPS antenna (GPS
information) generate the change of t he travel direction. Both have
advantages and disadvantages as per the following descriptions.
Input signals are prioritized in each situation. However, this order of priority may change in accordance with
more detailed travel conditions so that the tr avel direction is detected more accurately.
Map-matching
Map-matching repositions the vehicle on the road map when a new
location is judged to be more accurate. This is done by comparing
the current vehicle position (calculated by the normal position detec-
tion method) from the map data stored in the HDD (Hard Disk Drive).
There is a possibility that the vehicle position may not be corrected in the following case, and when vehicle is
driven over a certain distance or time in which GPS in formation is hard to receive. Correct manually the cur-
rent location mark on the screen.
In map-matching, several alternative routes are prepared and pri- oritized in addition to the road judged as currently driving on.
Therefore, due to errors in the distance and/or direction, an incor-
rect road may be prioritized, and the current location mark may be
repositioned to the incorrect road.
If two roads are running in parallel, they are of the same priority.
Therefore, the current location mark may appear on either of them
alternately, depending on maneuvering of the steering wheel and
configuration of the road, etc.
SEL684V
Type Advantage Disadvantage
Gyroscope (angular velocity
sensor) The turning angle is precisely detected.
Errors are accumulated when driving a long dis-
tance without stopping.
GPS antenna (GPS informa-
tion) The travel direction (North/South/East/West) is
detected. The travel direction is not precisely detected when
driving slowly.
SEL685V
SEL686V
Revision: 2010 May2011 QX56
Page 358 of 5598
AV-210
< SYMPTOM DIAGNOSIS >
NORMAL OPERATING CONDITION
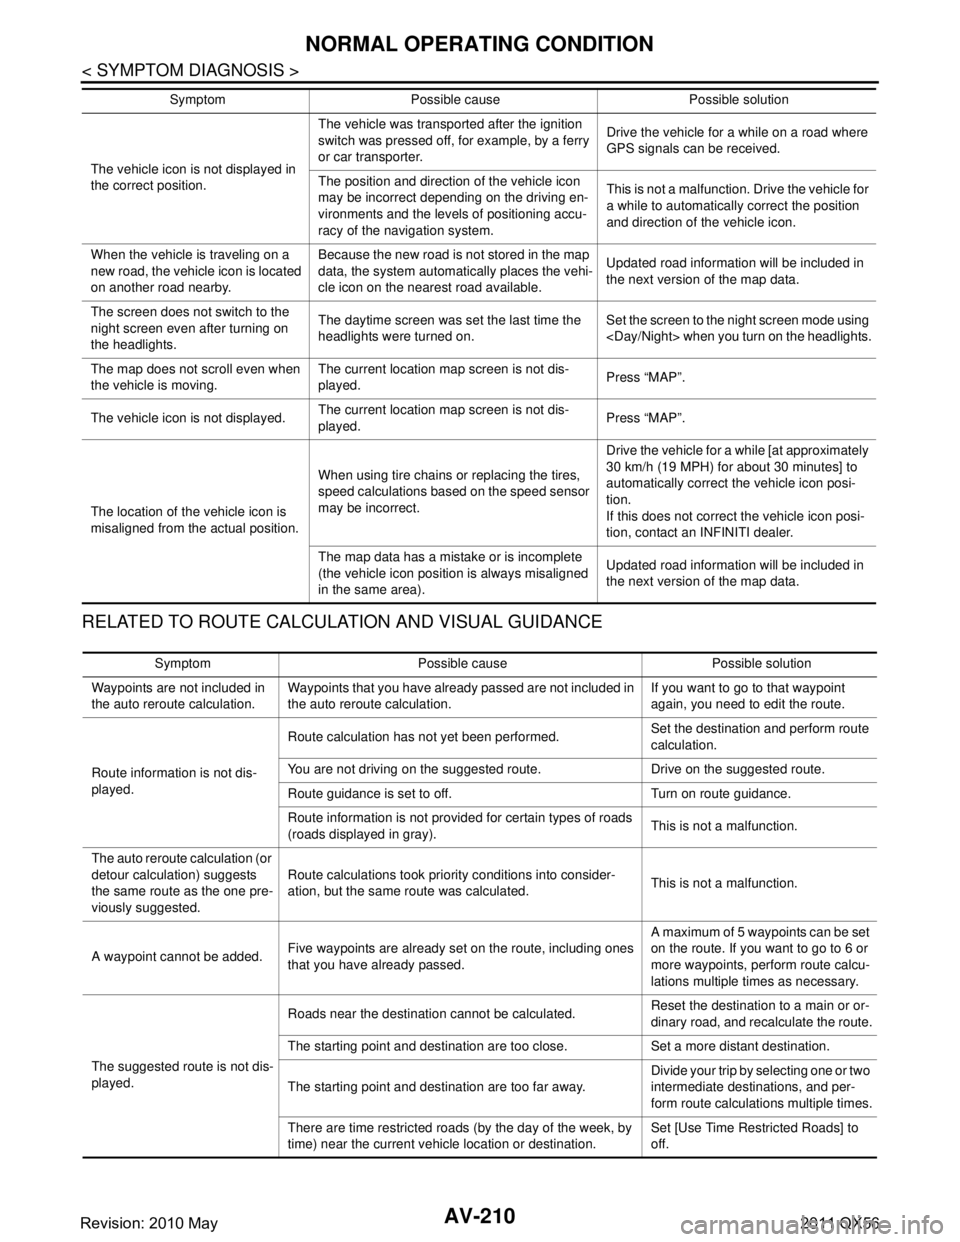
RELATED TO ROUTE CALCULATION AND VISUAL GUIDANCE
The vehicle icon is not displayed in
the correct position.The vehicle was transported after the ignition
switch was pressed off, for example, by a ferry
or car transporter.
Drive the vehicle for a while on a road where
GPS signals can be received.
The position and direction of the vehicle icon
may be incorrect depending on the driving en-
vironments and the levels of positioning accu-
racy of the navigation system. This is not a malfunction. Drive the vehicle for
a while to automatically correct the position
and direction of the vehicle icon.
When the vehicle is traveling on a
new road, the vehicle icon is located
on another road nearby. Because the new road is not stored in the map
data, the system automatically places the vehi-
cle icon on the nearest road available.
Updated road information will be included in
the next version of the map data.
The screen does not switch to the
night screen even after turning on
the headlights. The daytime screen was set the last time the
headlights were turned on.
Set the screen to the night screen mode using
The map does not scroll even when
the vehicle is moving. The current location map screen is not dis-
played.
Press “MAP”.
The vehicle icon is not displayed. The current location map screen is not dis-
played.
Press “MAP”.
The location of the vehicle icon is
misaligned from the actual position. When using tire chains or replacing the tires,
speed calculations based on the speed sensor
may be incorrect. Drive the vehicle for a while [at approximately
30 km/h (19 MPH) for about 30 minutes] to
automatically correct the vehicle icon posi-
tion.
If this does not correct the vehicle icon posi-
tion, contact an INFINITI dealer.
The map data has a mistake or is incomplete
(the vehicle icon position is always misaligned
in the same area). Updated road information will be included in
the next version of the map data.
Symptom Possible cause Possible solution
Symptom Possible cause Possible solution
Waypoints are not included in
the auto reroute calculation. Waypoints that you have already passed are not included in
the auto reroute calculation. If you want to go to that waypoint
again, you need to edit the route.
Route information is not dis-
played. Route calculation has not yet been performed.
Set the destination and perform route
calculation.
You are not driving on the suggested route. Drive on the suggested route.
Route guidance is set to off. Turn on route guidance.
Route information is not provided for certain types of roads
(roads displayed in gray). This is not a malfunction.
The auto reroute calculation (or
detour calculation) suggests
the same route as the one pre-
viously suggested. Route calculations took priority conditions into consider-
ation, but the same route was calculated.
This is not a malfunction.
A waypoint cannot be added. Five waypoints are already set on the route, including ones
that you have already passed. A maximum of 5 waypoints can be set
on the route. If you want to go to 6 or
more waypoints, perform route calcu-
lations multiple times as necessary.
The suggested route is not dis-
played. Roads near the destination cannot be calculated.
Reset the destination to a main or or-
dinary road, and recalculate the route.
The starting point and destination are too close. Set a more distant destination.
The starting point and destination are too far away. Divide your trip by selecting one or two
intermediate destinations, and per-
form route calculations multiple times.
There are time restricted roads (by the day of the week, by
time) near the current vehicle location or destination. Set [Use Time Restricted Roads] to
off.
Revision: 2010 May2011 QX56
Page 407 of 5598

BCS
DIAGNOSIS SYSTEM (BCM)BCS-19
< SYSTEM DESCRIPTION >
C
DE
F
G H
I
J
K L
B A
O P
N
ACTIVE TEST
HEADLAMP
HEADLAMP : CONSULT-III Func
tion (BCM - HEAD LAMP)INFOID:0000000006376461
WORK SUPPORT
PUSH SW
[On/Off] The switch status input from push-button ignition switch
UNLK SEN -DR
[On/Off] Driver door unlock status input from unlock sensor
DOOR SW-DR
[On/Off] The switch status input from door switch (driver side)
DOOR SW-AS
[On/Off] The switch status input from door switch (passenger side)
DOOR SW-RR
[On/Off] The switch status input from rear door switch RH
DOOR SW- RL
[On/Off] The switch status input from rear door switch LH
DOOR SW- BK
[On/Off] The switch status input from back door switch
CDL LOCK SW
[On/Off] Lock switch status input from door lock and unlock switch
CDL UNLOCK SW
[On/Off] Unlock switch status input from door lock and unlock switch
KEY CYL LK-SW
[On/Off] Lock switch status received from door key cylinder switch
KEY CYL UN-SW
[On/Off] Unlock switch status received from door key cylinder switch
TRNK/HAT MNTR
[On/Off] NOTE:
The item is indicated, but not monitored.
RKE-LOCK
[On/Off] Lock signal status received from remote keyless entry receiver
RKE-UNLOCK
[On/Off] Unlock signal status received from remote keyless entry receiver
Monitor item
[Unit] Description
Test item Operation Description
INT LAMP OnOutputs the interior room lamp control signal to turn the interior room lamps ON.
[Map lamp, personal lamp, foot lamp (when applicable lamps switch is in DOOR po-
sition.)]
Off Stops the interior room lamp control signal to turn the interior room lamps OFF.
STEP LAMP TEST On Outputs the step lamp control signal to turn the step lamps ON.
Off Stops the step lamp control signal to turn the step lamps ON.
Service item Setting item Setting
CUSTOM A/LIGHT SETTING MODE 1*
1Normal
MODE 2 More sensitive setting than normal setting (Turns ON earlier than normal opera-
tion)
MODE 3 More sensitive setting than MODE 2 (Turns ON earlier than MODE 2)
MODE 4 Less sensitive setting than normal setting (Turns ON later than normal operation)
Revision: 2010 May2011 QX56
Page 1240 of 5598
DAS
COMPONENT PARTSDAS-275
< SYSTEM DESCRIPTION > [LDW & LDP]
C
D
E
F
G H
I
J
K L
M B
N P A
LANE DEPARTURE PREVENTION (LDP) SYSTEM
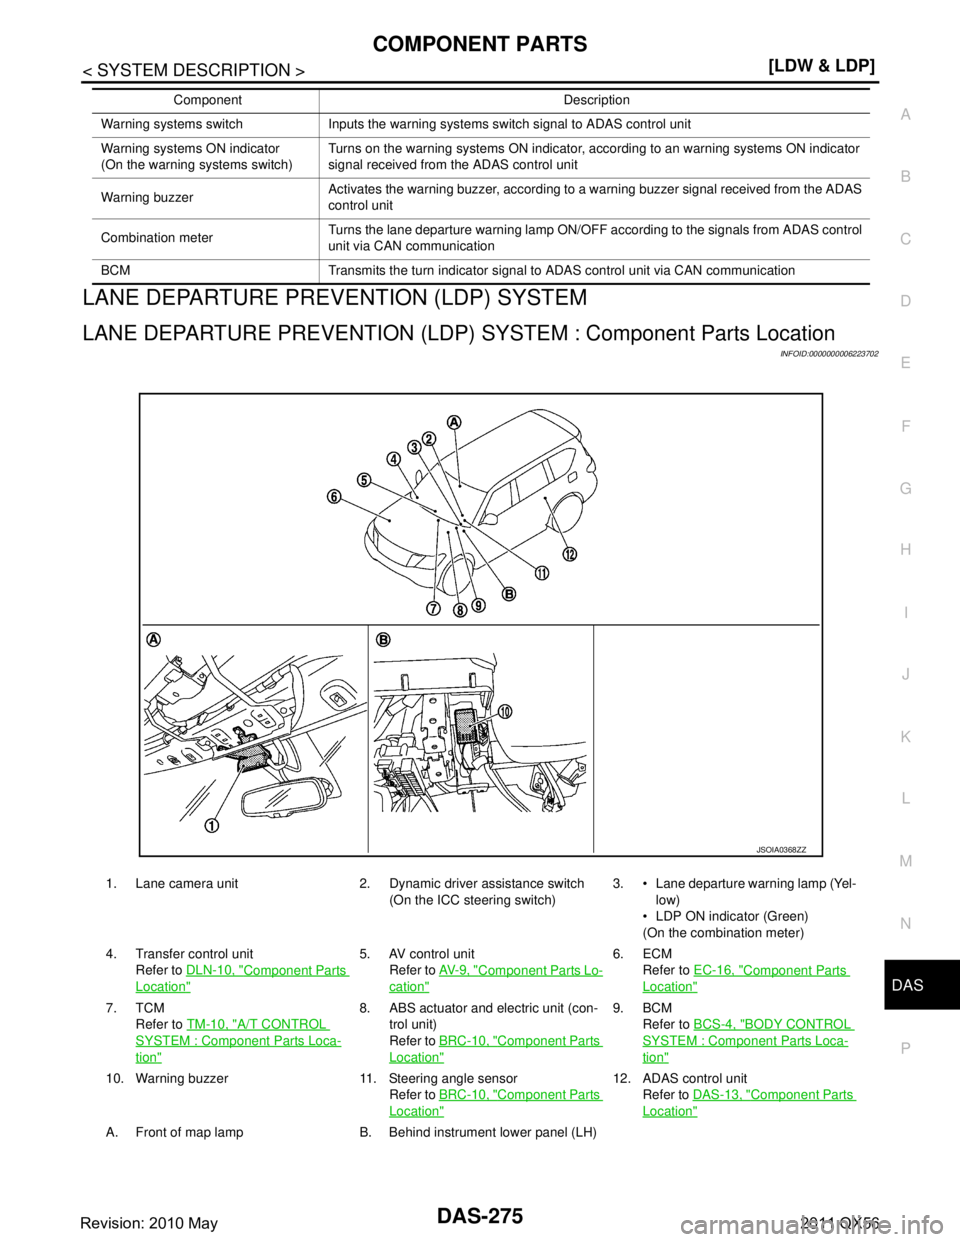
LANE DEPARTURE PREVENTION (LDP) SYSTEM : Component Parts Location
INFOID:0000000006223702
Warning systems switch Inputs the warning systems switch signal to ADAS control unit
Warning systems ON indicator
(On the warning systems switch) Turns on the warning systems ON indicator, according to an warning systems ON indicator
signal received from the ADAS control unit
Warning buzzer Activates the warning buzzer, according to a warning buzzer signal received from the ADAS
control unit
Combination meter Turns the lane departure warning lamp ON/OFF according to the signals from ADAS control
unit via CAN communication
BCM Transmits the turn indicator signal to ADAS control unit via CAN communication Component Description
1. Lane camera unit 2. Dynamic driver assistance switch
(On the ICC steering switch)3. Lane departure warning lamp (Yel-
low)
LDP ON indicator (Green)
(On the combination meter)
4. Transfer control unit Refer to DLN-10, "
Component Parts
Location"
5. AV control unit
Refer to AV- 9 , "
Component Parts Lo-
cation"
6. ECM
Refer to EC-16, "
Component Parts
Location"
7. TCM
Refer to TM-10, "
A/T CONTROL
SYSTEM : Component Parts Loca-
tion"
8. ABS actuator and electric unit (con-
trol unit)
Refer to BRC-10, "
Component Parts
Location"
9. BCM
Refer to BCS-4, "
BODY CONTROL
SYSTEM : Compon ent Parts Loca-
tion"
10. Warning buzzer 11. Steering angle sensor
Refer to BRC-10, "
Component Parts
Location"
12. ADAS control unit
Refer to DAS-13, "
Component Parts
Location"
A. Front of map lamp B. Behind instrument lower panel (LH)
JSOIA0368ZZ
Revision: 2010 May2011 QX56
Page 2027 of 5598
EC-3
C
DE
F
G H
I
J
K L
M
EC A
N
O P
Work Procedure ..................................................
..
147
IDLE AIR VOLUME LEARNING ......................148
Description .......................................................... ..148
Work Procedure ....................................................148
VVEL CONTROL SHAFT POSITION SEN-
SOR ADJUSTMENT .........................................
150
Description .......................................................... ..150
Work Procedure ....................................................150
MIXTURE RATIO SELF-LEARNING VALUE
CLEAR ..............................................................
152
Description .......................................................... ..152
Work Procedure ....................................................152
FUEL PRESSURE .......................................... ..153
Work Procedure .................................................. ..153
HOW TO SET SRT CODE ................................156
Description .......................................................... ..156
SRT Set Driving Pattern ........................................157
Work Procedure ....................................................159
DTC/CIRCUIT DIAGNOSIS .......................161
TROUBLE DIAGNOSIS - SPECIFICATION
VALUE ............................................................ ..
161
Description .......................................................... ..161
Component Function Check ..................................161
Diagnosis Procedure .............................................162
POWER SUPPLY AND GROUND CIRCUIT ....168
Diagnosis Procedure ........................................... ..168
U0101 CAN COMM CIRCUIT ...........................171
DTC Logic ........................................................... ..171
Diagnosis Procedure .............................................171
U1001 CAN COMM CIRCUIT ...........................172
DTC Logic ........................................................... ..172
Diagnosis Procedure .............................................172
U0113, U1003 CAN COMM CIRCUIT ..............173
DTC Logic ........................................................... ..173
Diagnosis Procedure .............................................173
U1024 CAN COMM CIRCUIT ...........................175
DTC Logic ........................................................... ..175
Diagnosis Procedure .............................................175
P0011, P0021 IVT CONTROL ..........................177
DTC Logic ........................................................... ..177
Diagnosis Procedure .............................................178
Component Inspection (Intake Valve Timing Con-
trol Solenoid Valve) ...............................................
179
P0031, P0032, P0051, P0052 A/F SENSOR 1
HEATER ...........................................................
181
DTC Logic ........................................................... ..181
Diagnosis Procedure .............................................181
Component Inspection (A/F Sensor 1 Heater) ......182
P0037, P0038, P0057, P0058 HO2S2 HEAT-
ER ....................................................................
184
DTC Logic ............................................................ ..184
Diagnosis Procedure .............................................184
Component Inspection (HO2 Sensor 2 Heater) .....186
P006A, P0101 MAF SENSOR ........................187
DTC Logic ..............................................................187
Diagnosis Procedure .............................................188
Component Inspection (MAF Sensor) ...................190
P0075, P0081 IVT CONTROL SOLENOID
VALVE .............................................................
193
DTC Logic ..............................................................193
Diagnosis Procedure .............................................193
Component Inspection (Intake Valve Timing Con-
trol Solenoid Valve) ...............................................
194
P0087, P0088, P0090 FRP CONTROL SYS-
TEM .................................................................
195
DTC Logic ..............................................................195
Diagnosis Procedure .............................................196
Component Inspection ...........................................196
P008A LOW FUEL PRESSURE CONTROL
SYSTEM ..........................................................
198
DTC Logic ............................................................ ..198
Diagnosis Procedure .............................................198
P008B LOW FUEL PRESSURE CONTROL
SYSTEM ..........................................................
200
DTC Logic ............................................................ ..200
Diagnosis Procedure .............................................200
P0102, P0103 MAF SENSOR .........................201
DTC Logic ..............................................................201
Diagnosis Procedure .............................................201
Component Inspection (MAF Sensor) ...................203
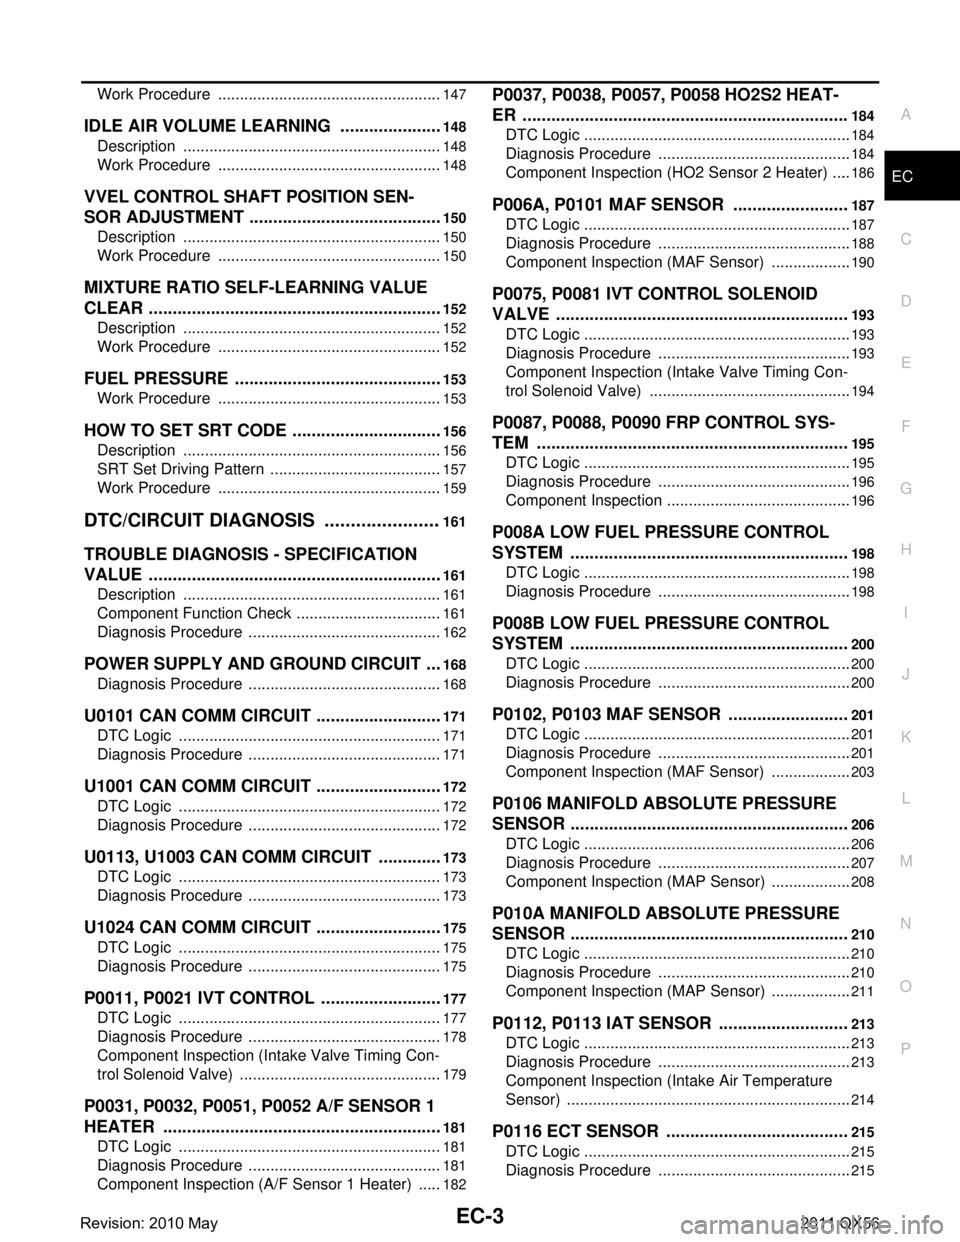
P0106 MANIFOLD ABSOLUTE PRESSURE
SENSOR ..........................................................
206
DTC Logic ..............................................................206
Diagnosis Procedure .............................................207
Component Inspection (MAP Sensor) ...................208
P010A MANIFOLD ABSOLUTE PRESSURE
SENSOR ..........................................................
210
DTC Logic ..............................................................210
Diagnosis Procedure .............................................210
Component Inspection (MAP Sensor) ...................211
P0112, P0113 IAT SENSOR ...........................213
DTC Logic ..............................................................213
Diagnosis Procedure .............................................213
Component Inspection (Intake Air Temperature
Sensor) ..................................................................
214
P0116 ECT SENSOR ......................................215
DTC Logic ..............................................................215
Diagnosis Procedure .............................................215
Revision: 2010 May2011 QX56
Page 2055 of 5598
COMPONENT PARTSEC-31
< SYSTEM DESCRIPTION > [VK56VD]
C
D
E
F
G H
I
J
K L
M A
EC
NP
O
Manifold Absolute Pressure SensorINFOID:0000000006217687
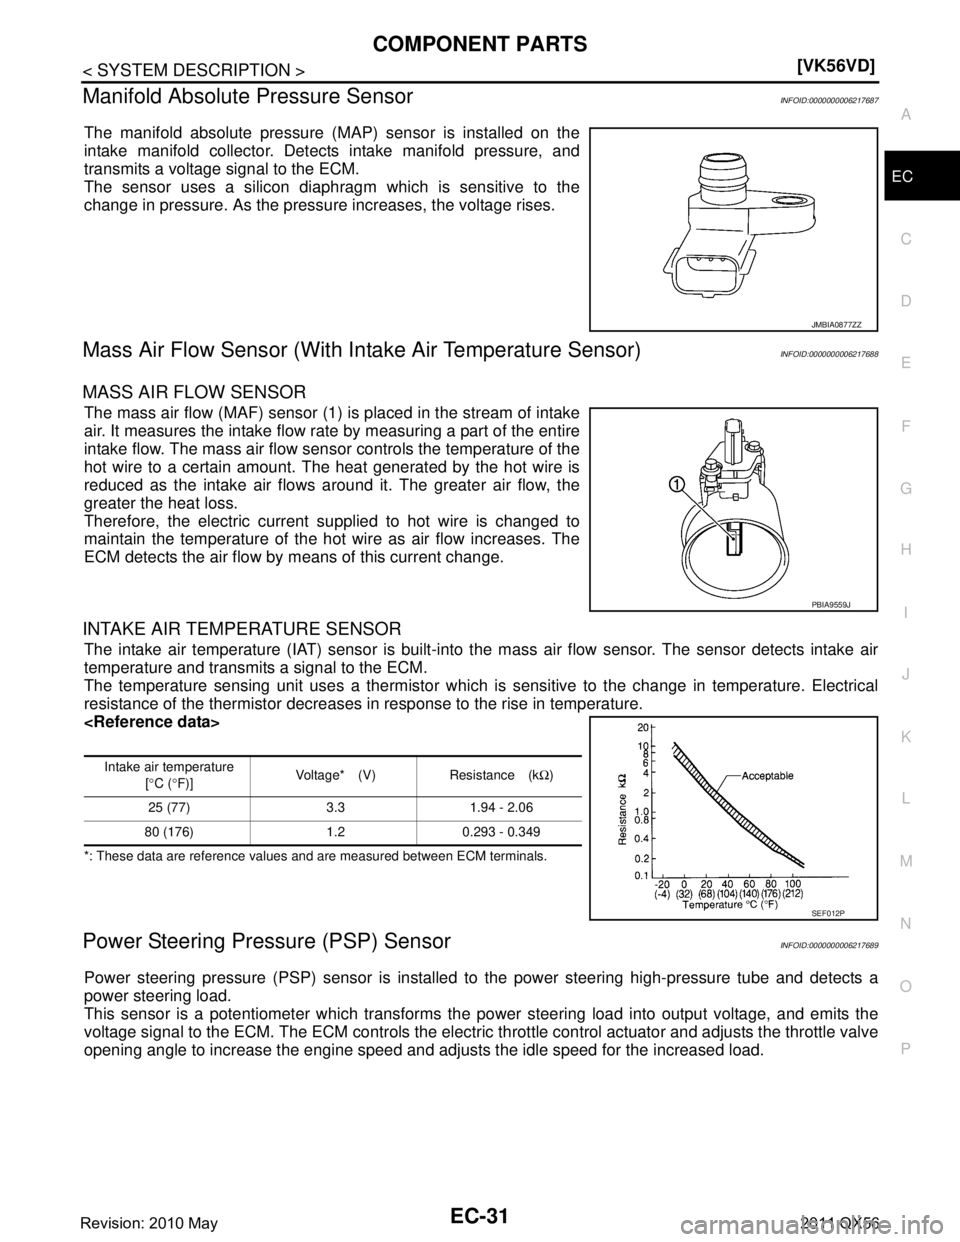
The manifold absolute pressure (MAP) sensor is installed on the
intake manifold collector. Detects intake manifold pressure, and
transmits a voltage signal to the ECM.
The sensor uses a silicon diaphragm which is sensitive to the
change in pressure. As the pressu
re increases, the voltage rises.
Mass Air Flow Sensor (With Intake Air Temperature Sensor)INFOID:0000000006217688
MASS AIR FLOW SENSOR
The mass air flow (MAF) sensor (1) is placed in the stream of intake
air. It measures the intake flow ra te by measuring a part of the entire
intake flow. The mass air flow sens or controls the temperature of the
hot wire to a certain amount. The heat generated by the hot wire is
reduced as the intake air flows around it. The greater air flow, the
greater the heat loss.
Therefore, the electric current supplied to hot wire is changed to
maintain the temperature of the hot wire as air flow increases. The
ECM detects the air flow by means of this current change.
INTAKE AIR TEMPERATURE SENSOR
The intake air temperature (IAT) sensor is built-into t he mass air flow sensor. The sensor detects intake air
temperature and transmits a signal to the ECM.
The temperature sensing unit uses a thermistor which is sensitive to the change in temperature. Electrical
resistance of the thermistor decreases in response to the rise in temperature.
*: These data are reference values and are measured between ECM terminals.
Power Steering Pressure (PSP) SensorINFOID:0000000006217689
Power steering pressure (PSP) sensor is installed to the power steering high-pressure tube and detects a
power steering load.
This sensor is a potentiometer which transforms the power steering load into output voltage, and emits the
voltage signal to the ECM. The ECM controls the electric throttle control actuator and adjusts the throttle valve
opening angle to increase the engine speed and adjusts the idle speed for the increased load.
JMBIA0877ZZ
PBIA9559J
Intake air temperature
[° C ( °F)] Voltage* (V) Resistance (k
Ω)
25 (77) 3.3 1.94 - 2.06
80 (176) 1.2 0.293 - 0.349
SEF012P
Revision: 2010 May2011 QX56