2020 MERCEDES-BENZ GLB SUV park assist
[x] Cancel search: park assistPage 189 of 602
Fu
nction ofOff-road ESP® Of
f-road ESP®
is activ ated aut omaticall ywhen
yo usele cttheF drive pr ogr am. Itint erve nes
la te rif th er eis ove rste er ing orunder steer ing,
th us improv ing traction .A spec ialETSsy stem
specif icallysuit edtooff-r oad terrain isalso acti‐
va ted. Ac
tiv atin g/deac tivatin gES P®
(E lectr onicSta‐
bil ity Prog ram) Mu
ltimed iasystem:
4 © 5
Set ting s5
Quick Access
% ESP®
can onlybe activ ated/deact ivat ed
using quick acc ess when atleas tone other
funct ionisavailable inqu ick acc ess. ESP®
can other wise befound intheAssist ance
menu. #
Select ESP.
A pr om ptappear s. #
Select Onor00BB Off. ES
P®
is deac tivated ifth e00BB ESP®
OFF warn‐
ing lam plight sup con tinuousl yin theins trument
clus ter.
Obser vetheinf ormation onwarning lam psand
displa ymess ages whic hma ybe sho wninthe
ins trumen tclus ter. Fu
nction ofESP ®
Cr osswind Assist ES
P®
Cr osswind Assistde tects sudde ngu stsof
side wind andhelps thedr iver tokeep theve hi‐
cle inthelane:
R ESP®
Cr osswind Assistis activ eat vehicle
speeds between appr ox.47 mp h(7 5 km/h)
and 125mp h(2 00 km/h) whendr iving
st ra ight ahead orcor ner ing slight ly.
R The vehicle isstabiliz edbymeans ofindivi d‐
ua lbr ak eapp lication onone side. Fu
nction ofEBD (electr onicbrak efo rc edis‐
tr ibut ion) EB
Dis ch aract erize dby thefo llo wing:
R Mon itor ing and regulating thebr ak epr essur e
on there ar wheels .
R Improve ddr iving stabilit ywhen brakin g,
espe ciallyon ben ds. Fu
nction ofSTEER CONT ROL ST
EER CONTR OLhelpsyo uby trans mitting a
no tice ablesteer ing forc eto thesteer ing wheel in
th edir ect ion requ ired forve hicle stabiliz ation.
This steer ing recomme ndation isgiv en particu‐
lar lyin thefo llo wing situat ions:
R Both right wheels orboth leftwheels areon
a we tor slip pe ry road sur face whe nyo u
br ak e
R The vehicle star ts to skid Dr
iving andparking 18
7
Page 190 of 602
Sy
stem limit s
ST EER CONTR OLmaybe impai redor ma yno t
func tion inthefo llo wing situat ions:
R ESP®
is deact ivat ed.
R ESP®
is malfun ctionin g.
R The steer ing ismalfunct ioning.
If ES P®
is malfunct ioning,youwill beassis ted
fur ther by theelectr icpo we rst eer ing. Fu
nction ofActiv eBr ak eAs sist Ac
tiveBr ak eAssi stconsi stsof thefo llo wing
func tions:
R Distan cewarning func tion
R Autonomo usbraki ng func tion
R Situ ation-d epend ent braki ng assist anc e
R Vehicl eswith Drivin gAss istanc ePa ck‐
ag e:Evasi ve Steer ing Assis tand corner ing
func tion
Ac tiveBr ak eAssi stcan helpyo uto minimize the
ri sk ofacollision withve hicles, cyclis tsor pedes
trians, orreduce theef fects ofsuch acol li‐
sion .
If Ac tiveBr ak eAssi sthas detected arisk ofcolli‐
sion, awa rning tone sou nds and theL dis‐
ta nce warning lam plight sup intheins trument
clus ter.
Ve hicl eswith PRE-S AFE®
:depe nding onthe
cou ntry,an addit ionalhap ticwarning occursin
th efo rm ofslight, repeat edtensi oni ng ofthe
seat belt.
If yo udo notre act tothewa rning, autono mous
br akin gcan beinit iated incritic alsituat ions.
In espec iallycritic alsituat ions,Ac tiveBr ak e
Assi stcan initia te aut onomo usbrakin gdir ect ly.
In this case, thewa rning lam pand warning tone
occu rsi mu ltane ously with thebr aking applica‐
tion .
If yo uappl yth ebr ak eyo urself inacr itical situa‐
tio nor appl yth ebr ak edur ing autonomous brak‐
ing, situation -dependen tbr aking assistance
occu rs.The brak epr ess ureincr eases uptomax‐
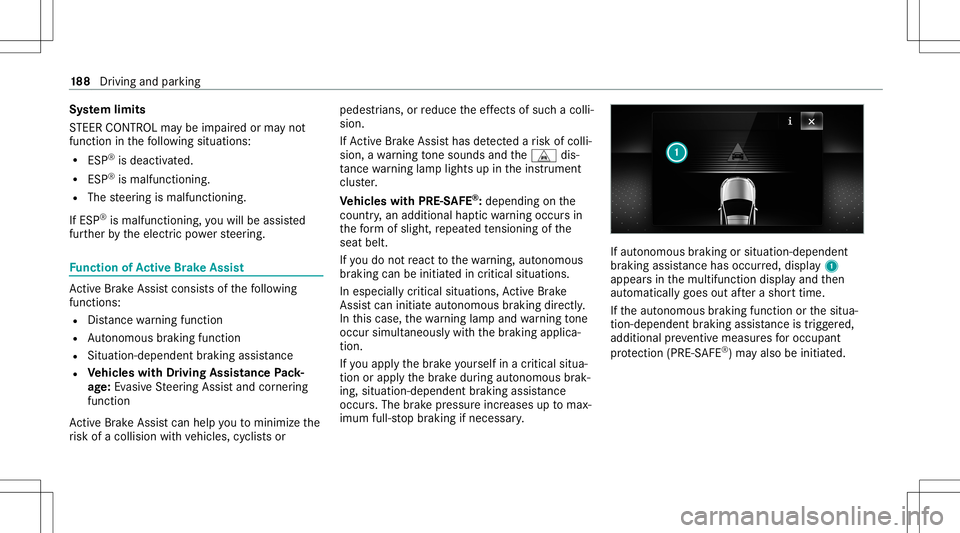
imum full-sto pbr aking ifnec essar y. If
aut onomous braking orsitua tion-dependent
br aking assistanc ehas occurred, displa y1
appear sin themultifunc tiondispla yand then
aut omaticall ygoes outafte ra shor ttime.
If th eaut onomous braking function orthesitua‐
tion -dependen tbr aking assistance istrig ge red,
additional preve ntiv emea suresfo roccupa nt
pr otect ion (PRE-S AFE®
)ma yalso beinitiat ed. 18
8
Driving and parking
Page 194 of 602
Situat
ion-dependent braking assistance mayint erve ne atspeeds star ting from appr oxima tely 4mp h(7 km /h)in thefo llo wing situations: Ve
hicl es
tr av eling in
fr ont St
ation ary
ve hicl es Cr
oss ing
ve hicl es Mo
ving
pedes trians St
ation ary
pedes trians Cr
oss ing
cy cli sts Cy
clis tstrave l‐
ing infront St
ation ary
cy cli sts
Ve hicles
wit hout Driv‐
ing Assis‐
ta nce Pack‐
ag e Up
toappr ox.
15 5mp h
(250 km/h) Up
toappr ox.
50 mph
(80 km/ h) No
react ion Uptoappr ox.
37 mph
(60 km/ h) No
react ion Uptoappr ox.
37 mph
(60 km/ h) Up
toappr ox.
50 mph
(80 km/ h) No
react ion
Ve hicles with
Dr iving Assis‐
ta nce Pack‐
ag e Up
toappr ox.
15 5mp h
(250 km/h) Up
toappr ox.
62 mph
(1 00 km/ h) Up
toappr ox.
43 mph
(70 km/ h) Up
toappr ox.
43 mph
(70 km/ h) Up
toappr ox.
43 mph
(70 km/ h) Up
toappr ox.
43 mph
(70 km/ h) Up
toappr ox.
50 mph
(80 km/ h) Up
toappr ox.
43 mph
(70 km/ h) Canceling
abr ak eapp lication ofActiv eBr ak e
As sist
Yo ucan cancelabr ak eapplic ationof Active
Br ak eAssi stat anytim eby :
R Fully depr essin gth eacceler ator pedal or
wit hkic kdo wn.
R Releasing thebr ak epedal. Ac
tiveBr ak eAssi stma ycancel thebr ak eappli‐
cation whenoneofthefo llo wing condition sis
fulf illed:
R Youman euvertoavo idtheobs tacle .
R The reisno long erarisk ofcollision.
R Anobs tacle isno long erdetected infront of
yo ur vehicle. Ev
asiv eSt eer ing Assis t(onl yve hicl eswith
Dr ivin gAss istanc ePa ckag e)
Ev asi ve Steer ing Assis thas thefo llo wing charac‐
te rist ics:
R The ability todetect statio naryor mo ving
pedes trians .
R Assis tance thro ugh powe r-assis tedsteer ing if
it de tects asw erving mane uver. 19
2
Driving and parking
Page 195 of 602

R
Activati on byan abr uptst eer ing movement
dur ing asw erving maneu ver.
R Assi stanc edur ing swervin gand stra ight enin g
of theve hicle.
R React ion from aspee dof appr oximat ely
12 mp h(20 km/h) uptoaspee dof appr ox‐
imat ely43 mph(70 km/h).
Yo ucan preve nttheassis tance atanytime by
act ivel yst eer ing.
Cor nering function (onlyve hicl eswith Driv‐
ing Assistanc ePa ckag e)
If adang erofcoll ision from anoncoming vehicle
is de tected whe ntur ning across anoncomi ng
la ne, autonomo usbraki ng can beinitia tedat
speeds below9mp h(1 5 km/h) beforeyo uha ve
lef tth elane inwhic hyo uar edr ivin g. &
WARNIN GRisk ofan acci dent despite
Ev asive St eer ing Assis t
Ev asiv eSt eer ing Assis tcann otalw aysclear ly
ident ifyobje ctsand complextraf fic situ a‐
tions . In
addition, thesteer ing suppor tof Evasiv e
St eer ing Assis tis ge ner ally no tsu fficien tto
av oid acollision.
In suc hcases Evasiv eSt eer ing Assis tcan:
R givean unnec essarywa rning orprov ide
assis tance
R notgi ve awa rning ornotpr ov ide assis‐
ta nce #
Alw ayspa ycar eful attention tothetra f‐
fi c situ ation; donotre ly on Evasiv e
St eer ing Assis talone. #
Beready tobrak eand take evasiv e
act ion ifnec essar y. #
Preve nttheassis tance byact ivel y
st eer ing innon -critical driving situa‐
tion s. #
Drive at an appr opriatespeed ifpedes‐
tr ians areclose tothepat hof your vehi‐
cle. Sy
stem limit s
Fu llsy stem perform anc eis no tav ailable fora
fe w sec ond saf te rswi tching ontheignition or
af te rdr iving off.
The system maybe impair edorma yno tfunc tion
in thefo llo wing situat ions:
R Insno w,rain, fog, hea vyspr ay,if th er eis
gl ar e, indir ect sunlight oringrea tly varying
ambien tlight .
R Ifth esensor sar edir ty,fo gg ed up, damag ed
or covered.
R Ifth esensor sar eim pair eddue tointerfer‐
ence from other radar sour ces, e.g.stro ng
ra dar reflect ions inpar king garage s.
R Ifaloss oftirepr essur eor afa ulty tirehas
been detected and displ aye d.
R IfDS Ris activ ated.
R Incom plextra ffic situat ionswher eobje cts
can notalw aysbe clear lyident ified.
R Ifpedes trians orvehicles movequickl yint o
th esensor detection rang e.
R Ifpe destrians arehidde nby other object s. Dr
iving andparking 19
3
Page 196 of 602

R
Ifth etypical outline ofapedes trian cann ot
be distinguished from thebac kground.
R Ifapedes trian isno tde tected assuch ,e.g.
due tospecial clothing orother object s.
R Onbends withatight radius.
% The ActiveBr ak eAssi stsensor sadjus taut o‐
matically whileacer tain dis tance isbe ing
dr iven afte rth eve hicle hasbeen delivered.
Ac tiveBr ak eAssi stisuna vailable oronl y
par tiall yav ailable during this teac h-in per iod. Se
tting Activ eBr ak eAs sist Re
quirement s:
R The ignit ionisswitc hedon.
Multime diasystem:
4 © 5
Set ting s5
Assist ance
5 Act ive Brak eAssist
The follo wing settings areav ailable:
R Early
R Medium
R Late #
Select ase tting .
The setting isretained when theengine is
ne xt star ted.
Deactiv atingActiv eBr ak eAs sist
% Itis recomme ndedthat youalw ayslea ve
Ac tiveBr ak eAssi stact ivat ed. #
Select Off.
The distance warning func tion,th eaut ono‐
mous braking function andtheEv asiv eSt eer‐
ing Assis tar edeactiv ated.
When theve hicle isne xt star ted, themiddle
se tting isaut omaticall yselect ed.
% IfAc tiveBr ak eAssi stisdeact ivat ed, the
00D4 symbol appearsinthest atus barofthe
multifu nctiondisplay. Speed
controlcruise contr ol Fu
nction ofcruise contr ol
Cr uise controlre gulat esthespeed totheva lue
selec tedby thedr iver .
If yo uacc elerat eto ove rtak e, forex am ple, the
st or ed speed isno tdele ted. Ifyo ure mo veyour fo
ot from theacceler ator pedal afte rove rtakin g,
cr uise control will resume speed regulation back
to thestor ed speed.
Cr uise controlis oper ated using thecor respond‐
ing steer ing wheel buttons. Youcan stor ean y
speed above15 mp h(2 0km/h) uptothemaxi‐
mum speed.
If yo ufa ilto adap tyo ur drivin gst yle, cruise con‐
tr ol can neither reduce therisk ofan accident
nor override thelaws ofphysics. Itcan nottak e
int oacc ount road, weather ortraf fic condi tions.
Cr uise contr olisonly anaid. The driver is
re sponsible forth edis tance totheve hicle in
fr ont, forve hicle speed, forbr aking ingood time
and forst ay ing inlane.
Displa ysinthemu ltifunct iondisp lay
The status ofcruise control and thestor ed
speed aresho wninthemultifunc tiondispla y. 19
4
Driving and parking
Page 200 of 602
%
The target speed alwaysadjus tsin1mp h
(1 km/ h)inc rements. Thisisrega rdless of
whe ther youpr ess thero ck er switc hto or
be yond thepoint ofresis tan ce. Ac
tiv eDi stance AssistDI ST RO NIC Fu
nction ofActiv eDi stance Assist
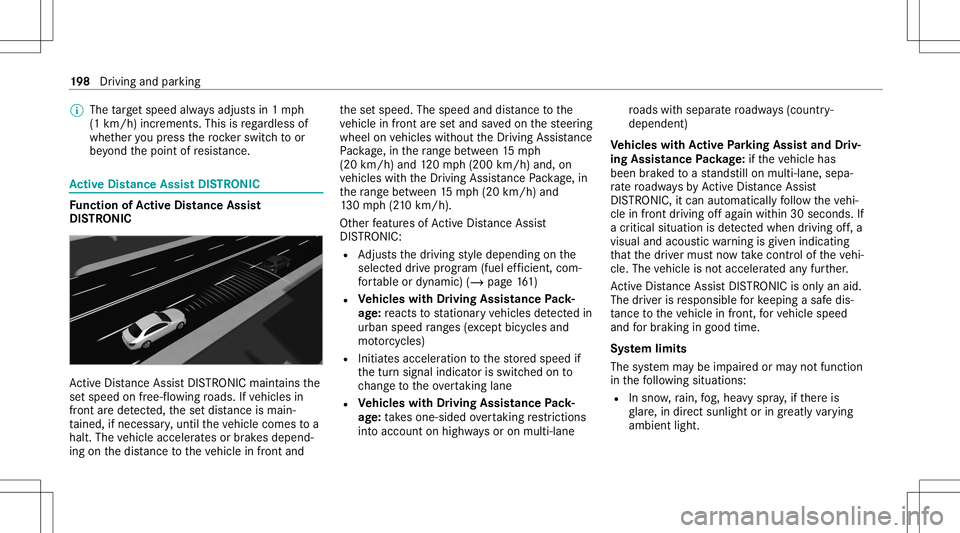
DI ST RO NIC Ac
tiveDis tance AssistDIS TRONI Cma intains the
se tspeed onfree-f lowing roads. Ifve hicles in
fr ont arede tected, these tdis tance ismai n‐
ta ined, ifnec essar y,unt ilth eve hicle comes toa
halt. Thevehicle acceler ates orbrak es depend‐
ing onthedis tance totheve hicle infront and th
ese tspeed. Thespeed anddistance tothe
ve hicle infront arese tand save don thesteer ing
wheel onvehicles without theDr iving Assistance
Pa ckag e, inthera ng ebe twee n15 mp h
(20 km/ h)and 120mp h(200 km/h) and,on
ve hicles withth eDr iving Assistance Packag e, in
th era ng ebe twee n15 mp h(20 km/h) and
13 0mp h(210 km/h) .
Ot her featur esofActiveDis tance Assist
DIS TRONI C:
R Adjus tsthedr iving style depending onthe
select eddrive pr ogr am (fuel efficie nt, com‐
fo rtable ordynam ic)(/ page16 1)
R Vehicl eswith Drivin gAss istanc ePa ck‐
ag e:react sto statio naryve hicles detected in
urb anspe edrang es (exc ep tbicy cles and
mo torcyc les)
R Initiates acc eler ation tothestor ed speed if
th etur nsignal indicat orisswitc hedonto
ch ang eto theove rtakin glane
R Vehicl eswith Drivin gAss istanc ePa ck‐
ag e:tak esone- sided overtakin gre strictions
int oacco untonhighwaysor on multi-lane ro
ads withseparat ero adw ays(countr y-
dependen t)
Ve hicl eswith Activ ePa rking Assis tand Driv‐
ing Assis tance Packag e:ifth eve hicle has
been brak ed toast ands tillon mult i-lane,sepa‐
ra te roadw aysby ActiveDis tance Assist
DIS TRONI C,itcan automatical lyfollo wtheve hi‐
cle infront driving offag ain within 30seconds. If
a cr itical situation isde tected whe ndr ivi ng off,a
vis ualand acoustic warning isgiv en indic ating
th at thedr iver mus tno wtake contr olof theve hi‐
cle. The vehicle isno tacceler ated anyfur ther.
Ac tiveDis tance AssistDIS TRONI Cis only anaid.
The driver isresponsible forke eping asaf edis‐
ta nce totheve hicle infront, forve hicle speed
and forbr aking ingood time.
Sy stem limit s
The system maybe impair edorma yno tfunc tion
in thefo llo wing situat ions:
R Insno w,rain, fog, hea vyspr ay,if th er eis
gl ar e, indir ect sunlight oringreat lyvarying
ambien tlight . 19
8
Driving and parking
Page 201 of 602

R
Ifth er eis swir ling dust,e.g. when driving off-
ro ad oron san dysur faces.
R The windsh ield inthear ea ofthecamer ais
dir ty,fo gg ed up, damag edorcovered.
R Ifth era dar sensor sar edir tyor covered.
R Inpar kingga rage sor on roads withsteep
uphill ordownhill gradients.
R Ifth er ear enar row vehicles infront, suchas
bicy cles ormo torcyc les.
In addition ,on slipper yro ads, brakin gor acc el‐
er atin gcan caus eon eor severalwheels tolose
tr act ion and theve hicle could then skid.
Do notuse ActiveDis tan ceAssi stDIS TRONI Cin
th ese situation s. &
WARNIN GRisk ofacci dent from acce ler‐
ati on orbraki ng byActiveDis tance
Assi stDIS TRONI C
Ac tiveDis tance AssistDIS TRONI Cma yacc el‐
er ateor brak ein thefo llo wing cases ,fo r
ex am ple:
R Ifth eve hicle pullsaway usin gAc tiveDis ‐
ta nce AssistDIS TRONI C.
R Ifth estor ed speed iscalled upand is
consider ablyfa ster or slo werth an the
cur rently driven spe ed.
R IfAc tiveDis tance AssistDIS TRONI Cno
lo ng er detects ave hicle infront ordoes
no tre act toreleva nt objects. #
Alw ayscar efully observethetraf fic con‐
di tions andbeready tobrak eat all
times. #
Take intoacc ount thetra ffic situat ion
bef orecallin gup thestor ed speed. &
WARNIN GRisk ofacci dent dueto insuf ‐
fi cie ntdece lera tio nby ActiveDis tance
Assi stDIS TRONI C
Ac tiveDis tance AssistDIS TRONI Cbrak es
yo ur vehicle withup to50% ofthemaximum
possible deceleration.Ifth is decele ratio nis
no tsu fficien t,Ac tiveDis tance Assist
DIS TRONI Caler ts youwit havis ual and
aco ustic warning. #
Inthese cases, adjustyo ur spee dand
ke ep asuf ficie ntdist anc e. #
Brak eth eve hicle yourself and/or take
ev asiv eact ion. &
WARNIN GRisk ofacci dent ifde tection
functi onofActiveDis tance Assist
DIS TRONI Cis impai red
Ac tiveDis tance AssistDIS TRONI Cdo es not
re act orhas alimit edreact ion:
R when drivin gon adif fere nt lane orwh en
ch ang inglane s Dr
ivin gand parking19
9
Page 202 of 602

R
topedes trians, animals, bicycles orsta‐
tio nar yve hicles, orune xpect edobs tacles
R tocom plex traf fic condi tions
R tooncom ingvehicles andcrossing traf fic
As are sult, ActiveDis tance Assist
DIS TRONI Cma ynei ther giv ewa rnings nor
int erve ne insuch situations. #
Alw aysobser vethetra ffic con dition s
car efull yand react accordin gly. Oper
ating Activ eDi stance AssistDI ST RO NIC
Re quirement s:
R The vehicle hasbeen star ted.
R The elect ric pa rking brak eis released.
R ESP®
is act ivat ed and isno tint erve ning .
R The trans mis sion isin po sitio n005B.
R The driver' sdo or isclo sed .
R Checkof thera dar sensor system has been
success fullycom pleted.
R Parking AssistPA RK TRONI Cis no tbein g
used topar kth eve hicle ortoexitfrom a
par kingspace. R
DSRis deact ivat ed.
R The vehicle does notskid.
Deactiv atingActiv eDi stance Assist
DI ST RO NIC : #
Press button 1. Ac
tiv atin gAc tiv eDi stance AssistDI ST RO NIC #
Toactiv atewi thout ast or ed speed :pr ess
ro ck er switc h3 up(SET +)or down (SET -),
or press rock er switc h4 up(RES). Remo ve
yo ur foot from theacceler ator pedal.
The current spe edisstor ed and maint ained
by theve hicle.
or #
Toactiv atewi th ast or ed speed :pr ess
ro ck er switc h4 up(RES). Remo veyour foot
fr om theacceler ator pedal.
% Bypressing rock er switc h4 upagain, the
speed limitation shownintheins trument
clus terwil lbe ado ptedby ActiveDis tance
Assi stDIS TRONI Cor variable limiter. #
Toacc eptth edisp laye dspe edrestriction
when Activ eDi stance AssistDI ST RO NIC
is ac tiv e:press rock er switc h4 up(RES).
The speed limitdispla yedin theins trument
clus teris ado ptedas thestor ed speed. The
ve hicle adaptsits speed tothat oftheve hicle
in front, butonlyup tothestor ed speed. 200
Driving andparking