1997 MERCEDES-BENZ ML320 radio code
[x] Cancel search: radio codePage 1573 of 4133

by the navigation processor Integrated Into the radio and navigation module (A2/56) .
During the switch-on phase (software is loaded), only basic map matching is available.
When the ignition is switched off all important location finding parameters are stored for the duration of the
shut-off delay (approx. 60 min) .
The permanent location finding feature uses three procedures which supplement each other ensuring very
precise and reliable location finding:
Basic location finding (dead reckoning)
Map-supported location finding (map matching)
GPS location finding
Manual entry of vehicle location
It is possible to enter the location manually on the operating and display module. This can be useful in the
following cases:
Following vehicle transport
(e.g. ferry or train) or
when GPS reception is not present when trip is started
LOADING LANGUAGE, FUNCTION - GF82.61-P-3003B
MODEL 163, 168, 170, 203.0 /2 /7, 208, 209.3 /4, 210 with CODE (353) Audio 30 APS
Function
The data for navigation voice output is stored originally on the navigation DVD. They are transmitted with the
help of the DVD drive of the radio (A2) into the memory of the navigation processor and are then available
anytime for navigation.
The language is reloaded in the following cases:
Basic location finding,
function GF82.61-P-3006GI
Global positioning system
location finding, function GF82.61-P-3007GI
Map-supported location
finding, function GF82.61-P-3008GI
Radio and navigation
module, location/purpose/
design/function GF82.61-P-4109GI
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 78 © 2006 Mitchell Repair Information Company, LLC.
Page 1574 of 4133

automatically, after voltage to the radio (A2) was interrupted
manually, by activating the "SPRA" menu in the navigation mode
Loading the language requires approx. 20 s.
If the system is switched off while loading the language, the language data is lost and must be reloaded again.
Avoid strong vibrations to the vehicle (e.g. extremely bumpy roads) while the language is being loaded.
The navigation processor is integrated in the radio (A2).
BASIC LOCATION FINDING, FUNCTION - GF82.61-P-3006D
MODELS 163, 168, 170, 203.0 /2 /7, 208, 209.3 /4, 210 with CODE (353) Audio 30 APS
Basic representation of the basic location finding shown on model 210
Basic location finding (dead reckoning) is the basic function of continuous location finding. It is permanently
carried out by the navigation processor that is integrated in the radio (A2) when the ignition is switched on
(approx. once per second) and is irrespective of the data of the DVD map. After switching off the ignition, the
current position is stored for the duration of the system shut-off delay time.
Fig. 46: Identifying Basic Location Finding Function
The following information is calculated with the aid of basic location finding:
Distance traveled
Absolute vehicle direction (compass direction)
Direction of travel (forward or reverse)
Calculation of distance traveled
The navi
gation processor receives the wheel speed signal of the following components:
Route calculation,
function GF82.61-P-3011E
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 79 © 2006 Mitchell Repair Information Company, LLC.
Page 1576 of 4133

BASIC LOCATION FINDING, FUNCTION - GF82.61-P-3006GI
MODEL 163 as of 1.9.01 with CODE (522) Modular control system (MCS) radio USA with CODE (357)
Navigation system - additional unit with CODE (818b) Single CD player - additional unit with CODE
(491) U.S. version
Fig. 47: Identifying Basic Location Finding, Function
Basic location finding (dead reckoning)
Is the basic function of permanent location finding It is accomplished permanently by the navigation processor
when the ignition is switched on and is not dependent on the CD-ROM map.
The current position is stored after the ignition is switched off.
The following information is calculated with the aid of basic location finding :
Distance traveled
Direction of motion (forward or backward) and
Direction in which vehicle is pointing
Basic location finding is accomplished approx. once per second .
Distance traveled
The navigation processor receives the signals output by the front right wheel speed sensor (L6/2) from the
traction system control module (N47) via discrete leads.
Evaluation of the wheel speed signals allows calculation of the distance traveled.
Direction of motion
Map-supported location
finding, function GF82.61-P-3008C
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 81 © 2006 Mitchell Repair Information Company, LLC.
Page 1577 of 4133

The navigation processor recognizes the direction of motion (forward or reverse) from the reverse signal.
Direction in which vehicle is pointing
From the data of the gyrosensor and the sequence of the locations calculated with GPS the navigation
processor the calculates the direction in which the vehicle is pointing (compass direction).
The difference between calculated and actual distance traveled between two turning points is used for automatic
recalibration of the tire circumference (required due to tire wear).
Location finding errors during basic location finding
Rolling backwards without the reverse gear engaged is evaluated as forward motion, and may lead to an error in
the location finding.
Rolling with the ignition switched off or vehicle transportation also falsify map matching.
In both cases the deviation is automatically corrected by the navigation processor after receiving GPS data .
Calibration
Wheel calibration is not required following tire change.
GLOBAL POSITIONING SYSTEM LOCATION FINDING, FUNCTION - GF82.61-P-3007C
MODEL 163, 168, 170, 203.0 /2 /7, 208, 209.3 /4, 210 with CODE (353) Audio 30 APS
Basic representation of the GPS location finding shown on model 210
Global positioning system
location finding, function GF82.61-P-3007GI
Map-supported location
finding, function GF82.61-P-3008GI
Guidance, function GF82.61-P-3012GI
Radio and navigation
module, location/purpose/
design/function GF82.61-P-4109GI
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 82 © 2006 Mitchell Repair Information Company, LLC.
Page 1579 of 4133
In addition, the vehicle's course of travel is determined with the aid of the sequence of the locations calculated
with GPS.
Possible interference when receiving GPS signals
Since GPS operates in the GHz range (microwaves) and the signals are weak, reception interference can occur
as the result of:
atmospheric interference, e.g. weather, water vapor, fog
multiple reception resulting from reflecting of signals, e.g. from building walls
Signal shadows, e.g., in built-up areas, tunnel, in the proximity of higher buildings and trees
GPS reception therefore necessitates a clear view of the sky. The location finding accuracy of the GPS system is
100 m or better.
GLOBAL POSITIONING SYSTEM LOCATION FINDING, FUNCTION - GF82.61-P-3007GI
MODEL 163 as of 1.9.01 with CODE (522) Modular control system (MCS) radio USA with CODE (357)
Navigation system - additional unit with CODE (818b) Single CD player - additional unit with CODE
(491) U.S. version
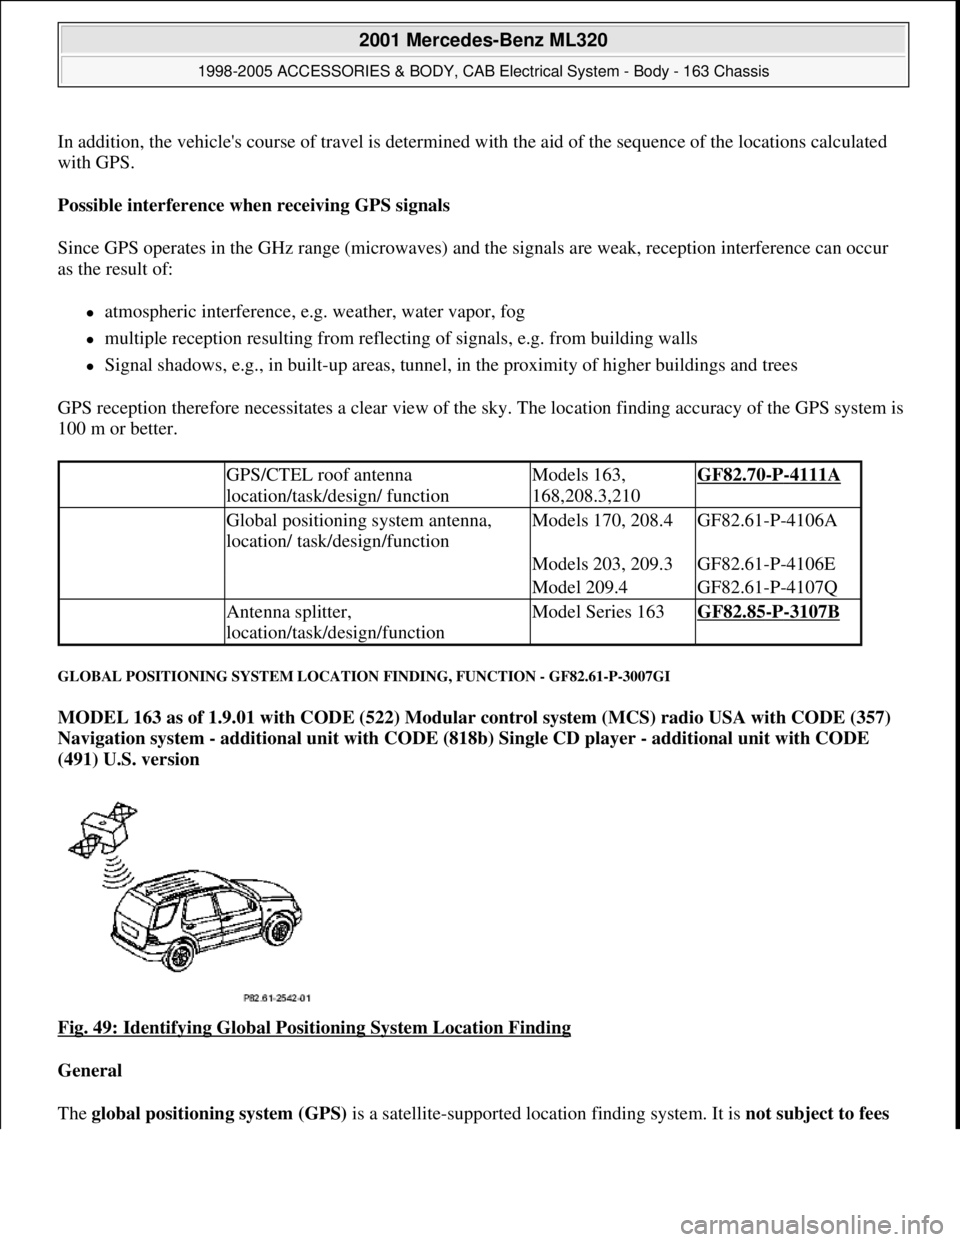
Fig. 49: Identifying Global Positioning System Location Finding
General
The global positioning system (GPS) is a satellite-supported location findin
g system. It is not subject to fees
GPS/CTEL roof antenna
location/task/design/ functionModels 163,
168,208.3,210GF82.70-P-4111A
Global positioning system antenna,
location/ task/design/functionModels 170, 208.4GF82.61-P-4106A
Models 203, 209.3GF82.61-P-4106E
Model 209.4GF82.61-P-4107Q
Antenna splitter,
location/task/design/functionModel Series 163GF82.85-P-3107B
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 84 © 2006 Mitchell Repair Information Company, LLC.
Page 1581 of 4133
MAP-SUPPORTED LOCATION FINDING, FUNCTION - GF82.61-P-3008C
MODEL 163, 168, 170, 203.0 /2 /7, 208, 209.3 /4, 210 with CODE (353) Audio 30 APS
Basic representation of the map-supported location finding shown on model 210
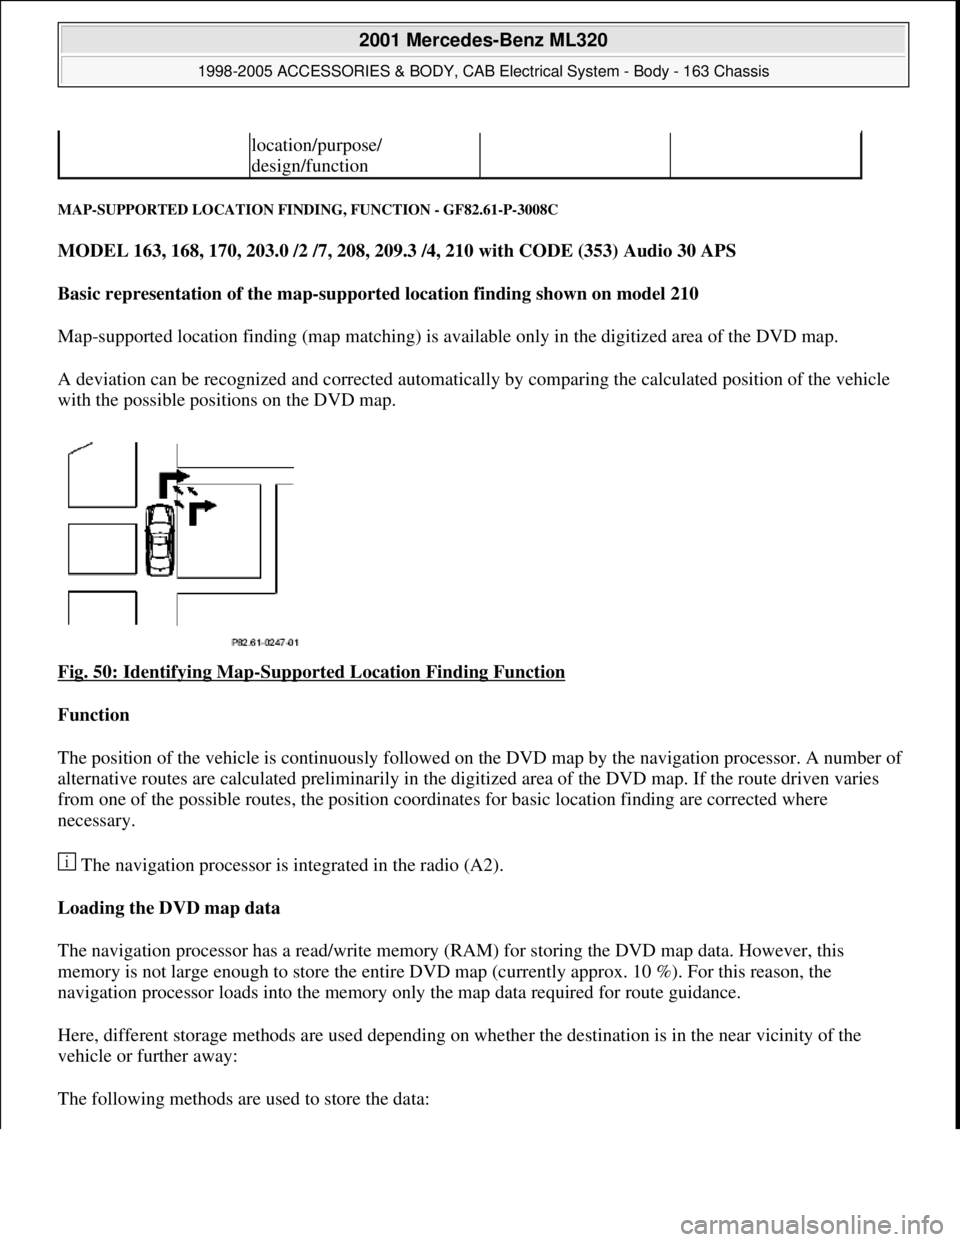
Map-supported location finding (map matching) is available only in the digitized area of the DVD map.
A deviation can be recognized and corrected automatically by comparing the calculated position of the vehicle
with the possible positions on the DVD map.
Fig. 50: Identifying Map
-Supported Location Finding Function
Function
The position of the vehicle is continuously followed on the DVD map by the navigation processor. A number of
alternative routes are calculated preliminarily in the digitized area of the DVD map. If the route driven varies
from one of the possible routes, the position coordinates for basic location finding are corrected where
necessary.
The navigation processor is integrated in the radio (A2).
Loading the DVD map data
The navigation processor has a read/write memory (RAM) for storing the DVD map data. However, this
memory is not large enough to store the entire DVD map (currently approx. 10 %). For this reason, the
navigation processor loads into the memory only the map data required for route guidance.
Here, different storage methods are used depending on whether the destination is in the near vicinity of the
vehicle or further away:
The followin
g methods are used to store the data:
location/purpose/
design/function
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 86 © 2006 Mitchell Repair Information Company, LLC.
Page 1582 of 4133
If the destination is in the near vicinity, a map area is loaded within a radius of approx. 100 km of the
vehicle location ("Local area").
For destinations further away, an area is selected surrounding the vehicle location, the destination and the
concrete route to the destination ("Corridor formation").
After storing the map data, the DVD with the map data can be taken out of the drive. Now, audio CDs can also
be played.
If the driver deviates too far from the calculated route during the course of navigation system and thereby leaves
the map area stored in the navigation processor, it may be necessary to insert the DVD again in order to
calculate a new route. The navigation processor requests this automatically.
Location errors
The errors are classified into 2 categories:
Incorrect position indication between 2 driving instructions (may not occur more than once every 500
km)
Incorrect driving instruction (may not occur more than once every 1,000 km)
MAP-SUPPORTED LOCATION FINDING, FUNCTION - GF82.61-P-3008GI
MODEL 163 as of 1.9.01 with CODE (522) Modular control system (MCS) radio USA with CODE (357)
Navigation system - additional unit with CODE (818b) Single CD player - additional unit with CODE
(491) U.S. version
General
Map-supported location finding is available only in the digitized area of the CD-ROM map.
By comparing the calculated vehicle position with the CD-ROM map it is possible to recognize and
automatically correct the deviation.
Function
The vehicle position is permanently followed by the navigation processor on the CD-ROM map. If the route
deviates from the calculated route the position coordinates of the basic location finding are corrected if
necessar
y.
Global positioning
system location finding,
function GF82.61-P-3007C
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 87 © 2006 Mitchell Repair Information Company, LLC.
Page 1583 of 4133
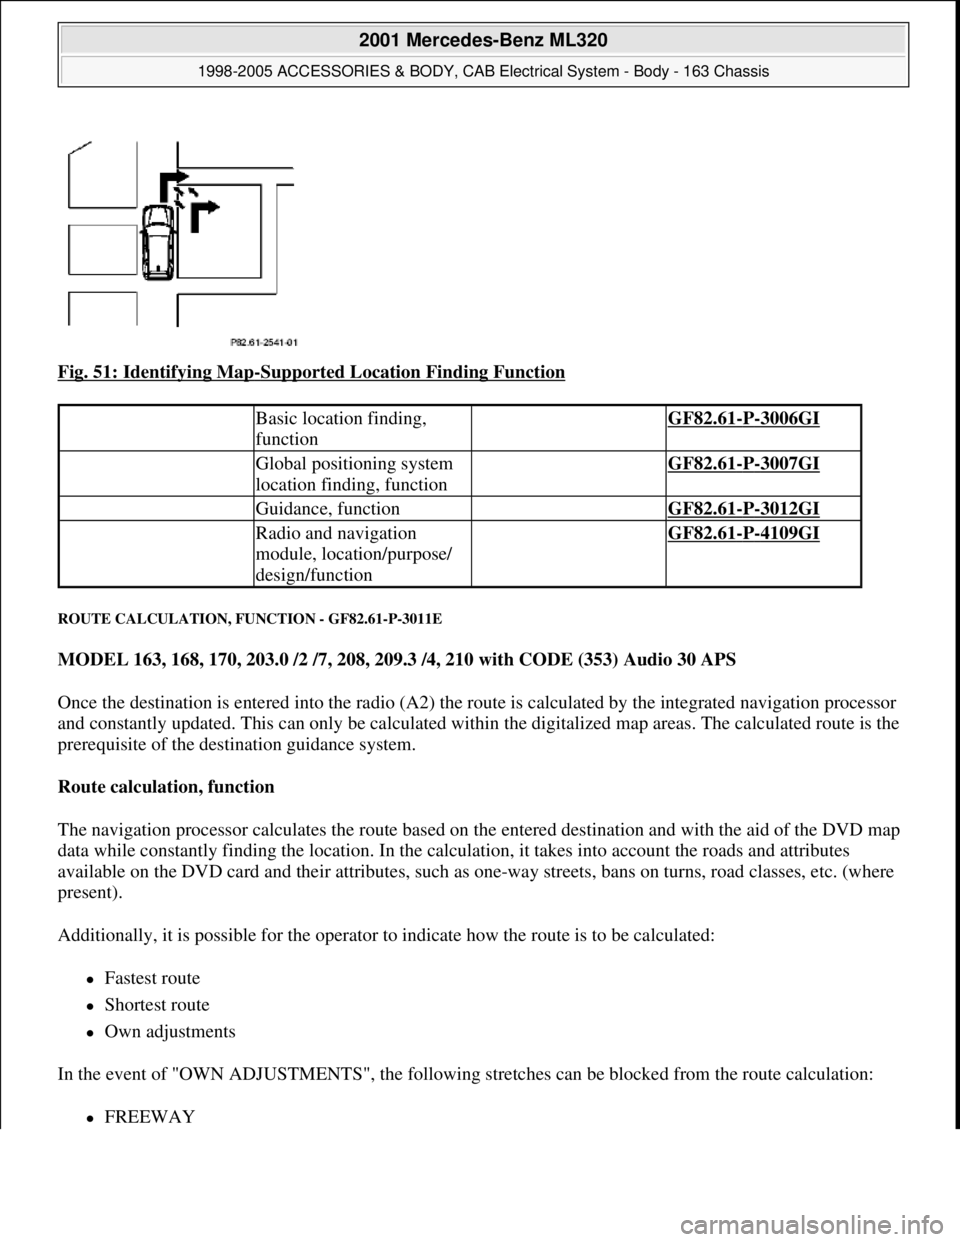
Fig. 51: Identifying Map-Supported Location Finding Function
ROUTE CALCULATION, FUNCTION - GF82.61-P-3011E
MODEL 163, 168, 170, 203.0 /2 /7, 208, 209.3 /4, 210 with CODE (353) Audio 30 APS
Once the destination is entered into the radio (A2) the route is calculated by the integrated navigation processor
and constantly updated. This can only be calculated within the digitalized map areas. The calculated route is the
prerequisite of the destination guidance system.
Route calculation, function
The navigation processor calculates the route based on the entered destination and with the aid of the DVD map
data while constantly finding the location. In the calculation, it takes into account the roads and attributes
available on the DVD card and their attributes, such as one-way streets, bans on turns, road classes, etc. (where
present).
Additionally, it is possible for the operator to indicate how the route is to be calculated:
Fastest route
Shortest route
Own adjustments
In the event of "OWN ADJUSTMENTS", the following stretches can be blocked from the route calculation:
FREEWAY
Basic location finding,
function GF82.61-P-3006GI
Global positioning system
location finding, function GF82.61-P-3007GI
Guidance, function GF82.61-P-3012GI
Radio and navigation
module, location/purpose/
design/function GF82.61-P-4109GI
2001 Mercedes-Benz ML320
1998-2005 ACCESSORIES & BODY, CAB Electrical System - Body - 163 Chassis
me
Saturday, October 02, 2010 3:30:05 PMPage 88 © 2006 Mitchell Repair Information Company, LLC.